

This is an old revision of the document!
Using a Digilent FPGA Github Demo's Releases (2020.1)
Warning
This page is for internal use only. It is intended to be embedded within other wiki pages and does not provide the full context necessary to use these steps
Hardware Only Release (Before Programming)
Note: This workflow is common across many Digilent FPGA demos. Screenshots may not match the demo you are working with.
Important: These steps are only to be used with releases for Xilinx tools versions 2020.1 and newer. Older releases may require other flows, as noted in the table of releases.
First, download and extract the '*.xpr.zip' file from the demo release page, linked above.
- Open a Vivado Project from a Release
-
Launch Vivado (Redirect)
This page has been moved, the new location is Launch Vivado.In Vivado's welcome screen, use the Open Project button to navigate to and open the XPR file contained in the folder the release was extracted into.


- Build a Vivado Project
-
Getting Started with Vivado for Hardware-Only Designs (Redirect)
This page has been moved, the new location is Getting Started with Vivado for Hardware-Only Designs.
Hardware Only Release (Programming)
- Program a Bitstream onto an FPGA Board
-
This page has been moved, the new location is Programming an FPGA Board through Vivado's Hardware Manager.
Baremetal Release (Before Programming, XSCT Scripts)
Note: This workflow is common across many Digilent FPGA demos. Screenshots may not match the demo you are working with.
Important: These steps are only to be used with releases for Xilinx tools versions 2020.1 and newer. Older releases may require other flows, as noted in the table of releases.
First, download the '*-hw.xpr.zip' and “Software source archive” files from the demo release page, linked above. Note that the hardware is included in the Assets list, while the software is linked from the description of the release.
The hardware (-hw) archive contains the Vivado project used to build the hardware platform for this demo. The project can be opened, modified, and used to update the hardware platform later if so desired, but this is optional. The software archive contains the software sources, hardware description file (XSA), and a set of scripts that can be used to rebuild the workspace.
Both files should be extracted.
Note: You may notice “-sw” archives in the release page's assets list. These importable archives should be ignored - a bug in Vitis 2020.1 prevents their use in some situations, and as such, the scripted method here is to be used instead.
- Recreate a Vitis Workspace from Source
-
Important: When selecting a workspace to open Vitis into, the use of the extracted software archive's “ws” folder is recommended. The use of this folder simplifies the process of invoking the script that recreates the projects.
This page has been moved, the new location is Launch Vitis.With Vitis open, in the menu bar at the top of the window, use the Xilinx → XSCT Console option to launch the Xilinx Software Command-line Tool.

In the XSCT Console, if you used the software archive's ws folder, enter the command below to run a script that recreates each of the projects and platforms associated with the demo from their sources.
source [getws]/../src/checkout.tcl
If you did not use the ws folder, find the path to the extracted archive, and enter the commands below. Note that all slashes in the path must be forward slashes (“/”) or the entire path must be enclosed in curly braces (“{}”).
source (path to software)/src/checkout.tcl
The checkout process may some time, though not more than a few minutes, as the projects are recreated and built. When complete, the “xsct%” prompt will reappear.


Baremetal Release (Before Programming)
Note: This workflow is common across many Digilent FPGA demos. Screenshots may not match the demo you are working with.
Important: These steps are only to be used with releases for Xilinx tools versions 2020.1 and newer. Older releases may require other flows, as noted in the table of releases.
First, download the '*.xpr.zip' and '*.ide.zip' files from the demo release page, linked above. The XPR archive contains the Vivado project used to build the hardware platform for this demo. The project can be opened, modified, and used to update the hardware platform later if so desired, but this is optional. The IDE archive contains a set of projects to be imported into a Vitis workspace.
Note: Unlike with Vivado XPR archives, do NOT extract the Vitis project archive ('*.ide.xip'). Vitis imports sources from the archive file directly.
- Import Vitis Projects from a Release
-
This page has been moved, the new location is Launch Vitis.
With Vitis open, click the Import Project button to import projects from a Vitis project exported zip file, then navigate to and select the IDE zip file you downloaded.

Make sure each project in the archive is checked, then click Finish to import them into your workspace.


- Build a Vitis Application
-
This page has been moved, the new location is Build a Vitis Application.
Baremetal Release (No Build)
Note: This workflow is common across many Digilent FPGA demos. Screenshots may not match the demo you are working with.
Important: These steps are only to be used with releases for Xilinx tools versions 2020.1 and newer. Older releases may require other flows, as noted in the table of releases.
First, download the '*.xpr.zip' and '*.ide.zip' files from the demo release page, linked above. The XPR archive contains the Vivado project used to build the hardware platform for this demo. The project can be opened, modified, and used to update the hardware platform later if so desired, but this is optional. The IDE archive contains a set of projects to be imported into a Vitis workspace.
Note: Unlike with Vivado XPR archives, do NOT extract the Vitis project archive ('*.ide.xip'). Vitis imports sources from the archive file directly.
- Import Vitis Projects from a Release
-
This page has been moved, the new location is Launch Vitis.
With Vitis open, click the Import Project button to import projects from a Vitis project exported zip file, then navigate to and select the IDE zip file you downloaded.
Make sure each project in the archive is checked, then click Finish to import them into your workspace.
Baremetal Release (Programming)
- Launch a Vitis Application
-
This page has been moved, the new location is Launch a Vitis Baremetal Software Application.
Baremetal Update Specification
In order to modify and switch out the hardware platform for a baremetal demo, you should first open the Vivado project from the release. Extract the previously downloaded '*.xpr.zip' file.
- Open a Block Design Project in Vivado
-
Launch Vivado (Redirect)
This page has been moved, the new location is Launch Vivado.In Vivado's welcome screen, use the Open Project button to navigate to and open the XPR file contained in the folder the release was extracted into.
The project's block diagram, which contains the design, with all of the existing components and their connections, can be opened by either double-clicking on the “*.bd” file in the sources pane (which also includes other source files, such as constraints), or by clicking the Open Block Design button in the Flow Navigator pane.

Making changes to the design is out of the scope of this particular document. More information on how to use IP Integrator to create or modify a project can be found through Getting Started with Vivado IP Integrator and Vitis (Redirect). The remainder of this document will discuss how to generate a bitstream, export a new hardware platform, and load it into Vitis.
This page has been moved, the new location is Validate a Block Design.

- Build a Vivado Project
-
This page has been moved, the new location is Build a Vivado Project.
- Export a Hardware Platform
-
This page has been moved, the new location is Export a Fixed Post-Synthesis Hardware Platform.
- Update a Hardware Platform in Vitis
-
This page has been moved, the new location is Update an Existing Vitis Platform's Hardware Specification.
Petalinux Release (Before Programming)
Note: This workflow is common across many Digilent Petalinux demos. Screenshots may not match the demo you are working with.
Important: These steps are only to be used with releases for Xilinx tools versions 2020.1 and newer. Older releases may require other flows, as noted in the table of releases.
First, download the '*.bsp' file from the demo release page, linked above.
- Open a Petalinux Project from a Release
-
Open a terminal and run the following commands. The install path is /opt/pkg/petalinux/ as exemplified in UG1144 v.2020.1. This will set up the Petaliunx environment for this terminal only.
source <path-to-installed-PetaLinux>/settings.sh
In the same terminal navigate to the desired project folder and create the Petalinux project using the '*.bsp' by executing the following command. The resulting folder structure will contain a pre-built folder which has the necessary boot binaries for the current Demo
cd <path-to-project-folder>
petalinux-create -t project -s <path-to-bsp>

- Build a Petalinux Project
-
In order to rebuild the project without changing anything in the configuration, first navigate to the root of the Petalinux project using the terminal which has the Petalinux environment set up.
Note: If the Petalinux environment is not set up it will not recognize the petalinux-* commands.
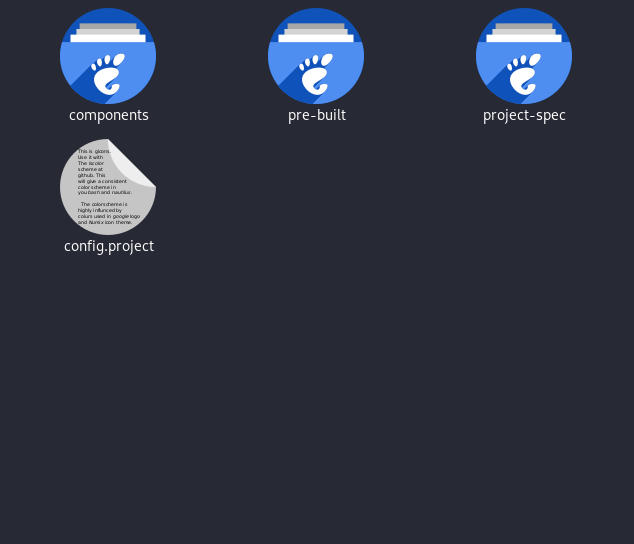
The root folder will contain the following folders and file: components, project-spec, pre-built (optional), config.project. Once in this folder execute the build command. This will start building the Petalinux project based on the current configuration. The execution time of the build command will depend on PC performance, project complexity, execution iteration (it takes longer for a clean project to build). Depending on the project complexity after the build, the project folder might take several GB of free space.
petalinux-build
After the build completion, the Boot.bin has to be explicitly built in order to have a Second Stage Boot Loader (SSBL) from Petalinux. This can be obtained by executing the command below from the root folder.
Note: <zynq_type> may vary depending on Zynq7000 or Zynq Ultra Scale
petalinux-package --boot --force --fsbl images/linux/<zynq_type>_fsbl.elf --fpga images/linux/system.bit --u-boot
Petalinux Release (Programming)
- Booting Petalinux on a Zynq Board
-
Copy the BOOT.BIN, boot.scr, image.ub files from the <path-to-project-folder>/images/linux or the <path-to-project-folder>/pre-built folder onto a FAT32 formatted MicroSD Card. Once this has been done, safely remove the SD Card from the PC and slide it into the development board's MicroSD Card slot. Make sure that the board is set up to boot from SD Card.
Note: Some projects might contain an extra file, uEnv.txt, which should be added to the SD Card
Boot up the board and set up your preferred serial console to listen on the serial port using the default baud rate of 115200. On the console, you should be able to see the boot-up sequence of the board starting from U-Boot (SSBL) up to the login prompt of Linux.
Note: The default login username and password is root:root
Petalinux Configurations
Note: This a brief summary of what Petalinux can do. For more details please refer to the UG1144 v.2020.1
There are some components that can be modified in Petalinux in order to customize your Linux environment. These include the user space application, kernel drivers, u-boot configuration, generic Petalinux settings, and Hardware update components. Most of these changes can be done by executing the petalinux-config command with different parameters.
Note: By using petalinux-config -c <COMPONENT> the component changes will be stored in the workspace directory (<project-root-dir>/components/yocto/workspace). To apply workspace changes to the recipe in the meta-user, the user must run the -x finish command to return their build location, for example, “petalinux-build -c <COMPONENT> -x finish”.
- Making Hardware Changes and Adding Them to Petalinux
-
In order to modify and switch out the hardware platform for a baremetal demo, you should first open the Vivado project from the release. Extract the previously downloaded '*.xpr.zip' file. Exporting the Vivado project for Petalinux is the same as exporting it for Vitis, therefore the instructions are identical.
- Open a Block Design Project in Vivado
-
Launch Vivado (Redirect)
This page has been moved, the new location is Launch Vivado.In Vivado's welcome screen, use the Open Project button to navigate to and open the XPR file contained in the folder the release was extracted into.
The project's block diagram, which contains the design, with all of the existing components and their connections, can be opened by either double-clicking on the “*.bd” file in the sources pane (which also includes other source files, such as constraints), or by clicking the Open Block Design button in the Flow Navigator pane.
Making changes to the design is out of the scope of this particular document. More information on how to use IP Integrator to create or modify a project can be found through Getting Started with Vivado IP Integrator and Vitis (Redirect). The remainder of this document will discuss how to generate a bitstream, export a new hardware platform, and load it into Vitis.
This page has been moved, the new location is Validate a Block Design.
- Build a Vivado Project
-
This page has been moved, the new location is Build a Vivado Project.
- Export a Hardware Platform
-
This page has been moved, the new location is Export a Fixed Post-Synthesis Hardware Platform.
- Importing the New Hardware
-
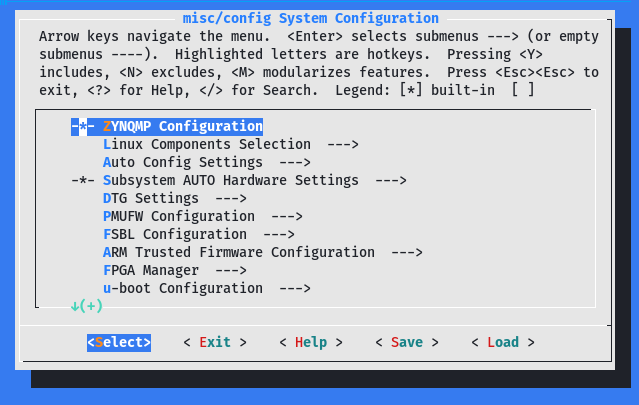
In order to import the new hardware description to Petalinux, the following command must be executed. This will prompt a configuration window where all the new Zynq generic changes for the new hardware will be visible.
petalinux-config --get-hw-description=<path-to-new-xsa>
Other changes which can be configured from this window are: boot-flow, default password, FPGA reconfiguration, image packaging, and other important settings. This window can also be accessed by simply executing petalinux-config without any parameters.
petalinux-config

- Configuring U-boot
-
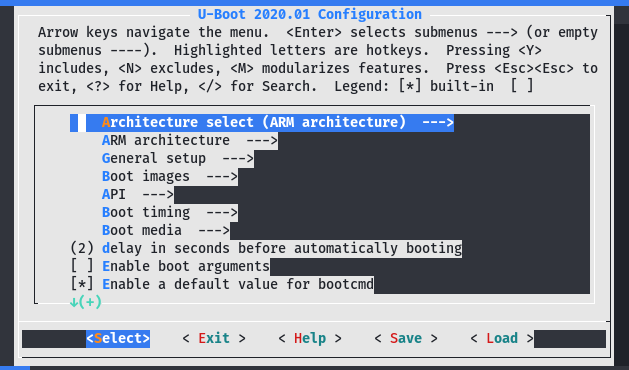
When first importing the hardware, some U-boot customization is generated by the import feature. U-boot customization includes drivers for boot mediums, file system support, boot console arguments, network support, and many more. In order to bring up the configuration window, the following command must be executed.
petalinux-config -c u-boot

- Configuring the Kernel
-
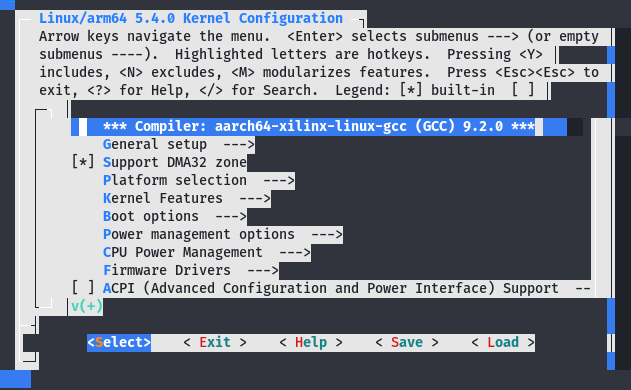
When first importing the hardware, some kernel customization is generated by the import feature, which usually includes supported drivers for PL IPs. U-boot customization includes drivers for drivers, logging levels, debugging flags, and many more. In order to bring up the configuration window, the following command must be executed:
petalinux-config -c kernel

- Configuring the RootFS
-
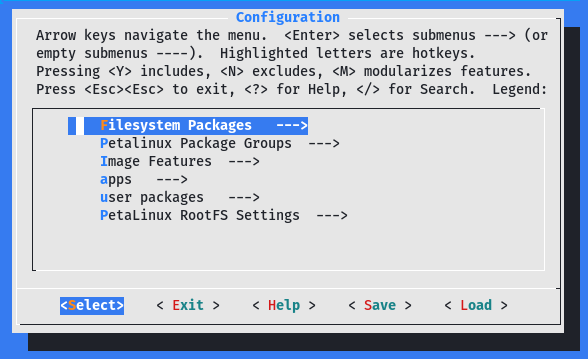
The packages which will be built into the rootfs need to be added manually by the user. The default package manager for Petalinux currently is RPM and any additional packages which the user wants to add need to be built using Petalinux. In order to bring up the configuration window, the following command must be executed:
petalinux-config -c kernel

- Changes to the Device Tree
-
When first building the project by executing petalinux-build or if you are using the *.bsp version of the project, the generated device tree will be available in <path-to-project-folder>/components/plnx_workspace/device-tree/device-tree. Any changes to this folder will be overwritten at the next build. In order to make permanent changes, the <path-to-project-folder>/project-spec/meta-user/recipes-bsp/device-tree/files/*.dtsi need to be changed.
Note: Changes to the device tree components will have to be done by referring to the already existing nodes in the auto-generated device trees.
Warning
After configuring some of the previous settings might be lost. This is a known issue in Petalinux 2019.2 and 2020.1; more information about the workaround can be found here Xilinx Forum
Baremetal Release Workaround (Before programming)
- Apply Fix for Vitis 2020.1 Bug
-
Due to a bug in the 2020.1 version of Xilinx's Vitis IDE, two more steps are needed for the project to import correctly. If you are using another version of Vitis, ignore this section.
After importing the project, open the .sprj file. In the System Project Settings, select a platform by clicking on the
…icon, as shown in the image. Select the platform presented and click Ok.
Right click on the .prj file and select Properties. In the opened window, go into C/C++ Build and select Settings, as shown in the image. After opening the Settings tab, select Linker Script and change the existing path to
../src/lscript.ld. Click Apply and Close.The project is now imported correctly.


